48V — Humanoid Robot Joint Drive Selection SiNESEMI SGT MOSFET Model List
2026.10.22
4 次
SMT10T08ALR PDFN3.3×3.3 space-saving MOSFET low-to-medium power humanoid robot joint MOS elbow joint MOSFET for 48V humanoid robot
SMT10T08ALR PDFN3.3×3.3 space-saving MOSFET

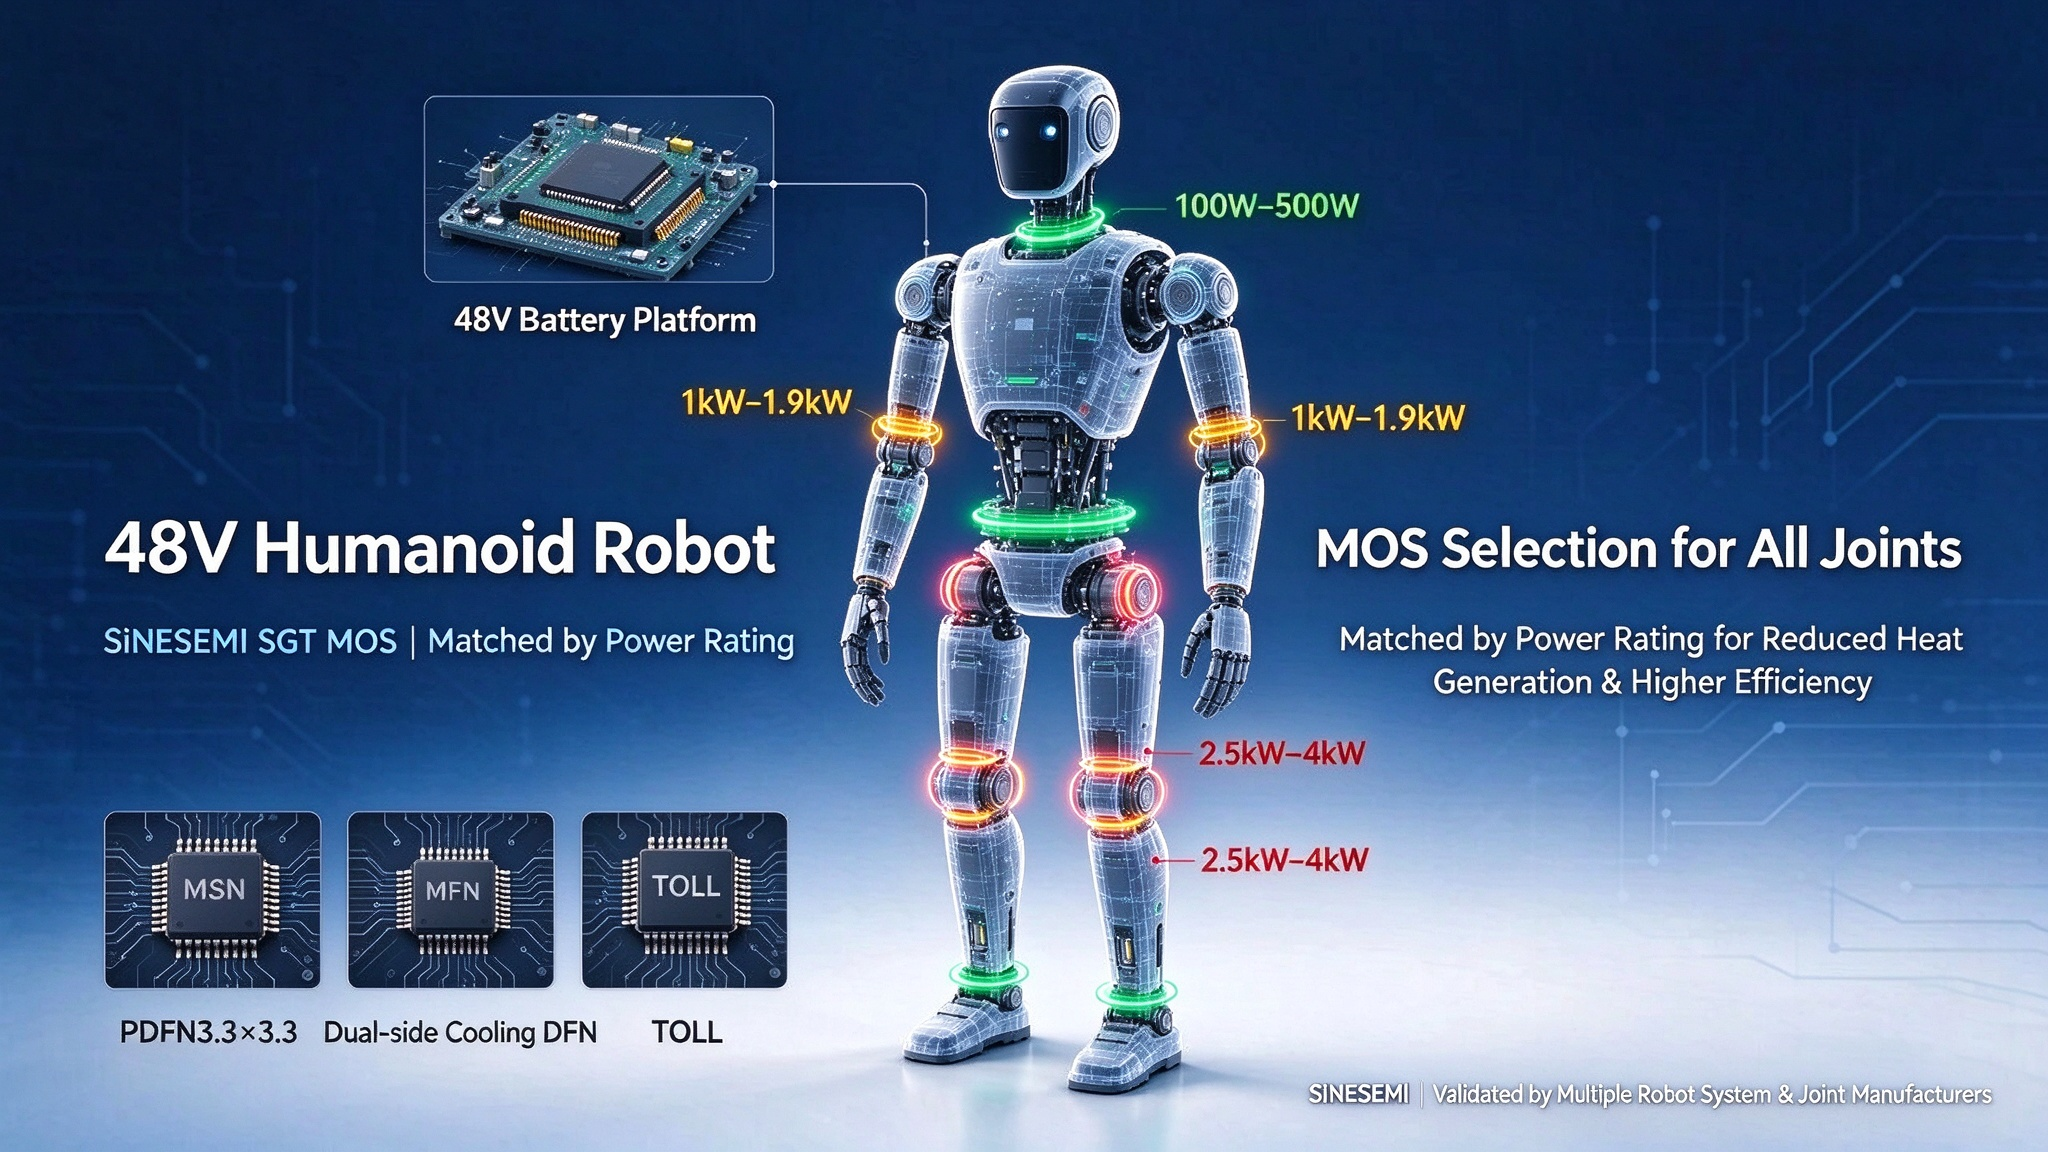
48V is currently the most mainstream battery voltage platform for humanoid robots. However, power requirements vary drastically across different robot joints: ankles and shoulders fall into the low-to-medium power category, while hip and knee joints need high power output of 2.5–4 kW. Improper MOSFET selection will lead to severe overheating and reduced system efficiency.

SiNESEMI provides a complete device selection list tailored for different joints on 48V humanoid robots:

公众号推文翻译.jpeg


1. Ankle, Shoulder, Waist & Neck Joints

(Power range: 100W–500W) Recommended Part: SMT10T08ALR(Package: PDFN3.3×3.3)

These medium & low-power joints are highly sensitive to footprint. The compact PDFN3.3×3.3 package saves PCB space perfectly for small-to-medium body joints.

2. Elbow Joint

(Power range: 1.0kW–1.9kW) Recommended Parts: SMT10T02AHP SMT10T02AHPDC

Medium power level with balanced conduction loss & switching loss. The double-sided cooling variant works well inside joint cavities with limited heat dissipation.

3. Hip & Knee Joints

(High power: 2.5kW–4kW) Recommended Parts: SMT10T0SAHTL SMT10T01EHTL SMT10T01BHTL2

Hips and knees consume the highest power on humanoid robots. TOLL-package MOSFETs with ultra-low Rds(on) are required to withstand large current surges.

4. Whole-Robot DC-DC Power System

Recommended Parts: SMT10T08AHPB SMT3001BLP

Optimized for 48V-to-12V and 12V-to-5V power conversion rails.

1. Ankle, Shoulder, Waist & Neck Joints

(Power range: 100W–500W) Recommended Part: SMT10T08ALR(Package: PDFN3.3×3.3)

These medium & low-power joints are highly sensitive to footprint. The compact PDFN3.3×3.3 package saves PCB space perfectly for small-to-medium body joints.


公众号推文翻译.png

SiNESEMI’s 48V platform SGT MOSFETs have been validated by multiple humanoid robot OEMs and integrated joint actuator manufacturers.


?Selection Tips:

  • Compact PDFN packages are ideal for space-constrained medium/low-power joints.

  • TOLL and double-sided cooling packages greatly cut thermal resistance, perfect for high-power joints.

  • SGT-process MOSFETs deliver low Rds(on) plus outstanding switching performance with excellent FOM (Figure of Merit), ideal for high-frequency FOC motor drives.